
Question
A frame of reference that is accelerated with respect to an inertial frame of reference is called a non-inertial frame of reference. A coordinate system fixed on a circular disc rotating about a fixed axis with a constant angular velocity ω is an example of a non-inertial frame of reference.
The relationship between the force experienced by a particle of mass m moving on the rotating disc and the force experienced by the particle in an inertial frame of reference is
where is the velocity of the particle in the rotating frame of reference and is the position vector of the particle with respect to the centre of the disc.
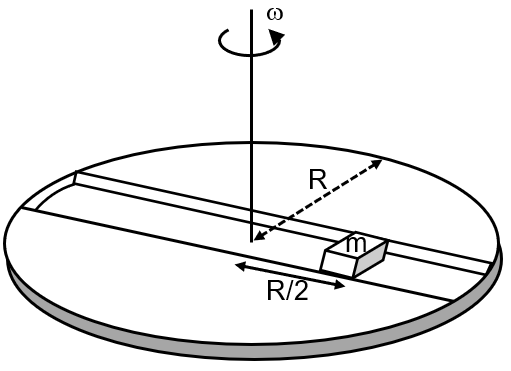
Now consider a smooth slot along a diameter of a disc of radius R rotating counter-clockwise with a constant angular speed ω about its vertical axis through its center. We assign a coordinate system with the origin at the center of the disc, the x-axis along the slot, the y-axis perpendicular to the slot and the z-axis along the rotation axis . A small block of mass m is gently placed in the slot at at t = 0 and is constrained to move only along the Slot.

Know your College Admission Chances Based on your Rank/Percentile, Category and Home State.
Get your JEE Main Personalised Report with Top Predicted Colleges in JoSA
The distance r of the block at time t is
The net reaction of the disc on the block is:
Coriolis force
Net reaction